An inverse is supposed to undo an operation. OpenAI’s September 23, 2026 preprint constructs two finite algebraic expressions that undo each other in one order and fail in the other. The Kaplansky Direct Finiteness Conjecture predicted that this could never happen in a group algebra. The paper presents a characteristic-two counterexample, with a finitely presented infinite group and consequences for cellular automata.
The surprise is how it works. Finite geometry supplies cancellations, group embeddings preserve the evidence, and an elementary rank argument detects the failure. The construction is specified by a terminating search, but that search has not been executed. Understanding both the theorem and that limitation is essential.
Table of Contents
1. What Is the Kaplansky Direct Finiteness Conjecture?
A group algebra combines coefficients from a field with elements of a group . Its elements are formal sums with finite support, meaning only finitely many coefficients are nonzero. Multiplication distributes across the sums, multiplying coefficients in the field and group elements in their original order.
For example, multiplying gives . Matching group elements combine through field addition.
Finite support belongs to each algebra element individually. It does not confine every calculation to a finite group: repeatedly multiplying support elements can generate infinitely many distinct group elements. That distinction explains why the finite-dimensional argument for finite groups cannot simply be recycled for every group algebra. A ring is directly finite when always forces . This is distinct from the Kaplansky zero-divisor question, which concerns nonzero factors multiplying to zero under a torsion-free hypothesis.
1.1. Key Facts About the Counterexample
| Feature | Precise Scope |
|---|---|
| Manuscript | OpenAI, September 23, 2026; 28 pages. |
| Coefficient field | Finite, characteristic two; not asserted to be exactly . |
| Constructed group | Infinite and finitely presented, containing odd-prime torsion. |
| Scalar witnesses | Finite sums with and . |
| Construction status | Terminating prescription proved; full search not executed. |
| Further consequences | The same group is nonsofic and admits an injective, nonsurjective cellular automaton. |
Infinite-dimensional shifts explain why failure is conceivable. On a basis indexed by nonnegative integers, let shift right and shift left, sending the first basis vector to zero. Then , while kills that first vector. These operators illustrate asymmetry. They are not the paper’s group-algebra witnesses.
2. Why Previous Proofs Could Not Settle the General Conjecture
For finite groups, group algebras have finite dimension over their coefficient fields. An injective linear map on a finite-dimensional space is surjective, so a one-sided inverse must work both ways. The same argument covers every finite square matrix size.
For arbitrary groups in characteristic zero, operator-algebra trace methods replace finite dimension. The complex group algebra sits inside a finite tracial setting, which rules out proper one-sided inverses. Finitely many coefficients over any characteristic-zero field lie in a subfield embeddable in the complex numbers. Our group-factor explainer introduces the surrounding operator-algebra language.
Elek and Szabó’s theorem establishes stable finiteness for sofic group algebras over arbitrary division rings. Soficity means finite pieces of multiplication admit sufficiently accurate finite approximate models. Amenability supplies another important positive setting, with background in our Thompson’s group analysis.
Stable finiteness requires direct finiteness in every finite square matrix ring. A matrix counterexample therefore needs an additional argument before it becomes a counterexample involving two ordinary group-algebra elements.
3. OpenAI’s Characteristic-Two Counterexample: The Exact Theorem
Theorem 1.1 of the original 28-page paper states that there exist a finite characteristic-two field , a finitely presented group containing an element of odd prime order, and finite sums satisfying:
Finite presentation means finitely many generators and defining relations. It does not mean the group is finite. Indeed, the finite-dimensional argument forces this group to be infinite.
Characteristic two means . It does not specify that . The coefficient field must also contain roots of unity needed later. A root of unity is a field element whose specified positive power equals one. Odd-order torsion, meaning nonidentity elements of finite odd order, is deliberately retained.
OpenAI places the manuscript within its October mathematics release, produced by an internal frontier model. The mathematical claim should be assessed through its argument and verification artifacts. The theorem concerns existence and exact algebraic identities, without an application benchmark or demonstrated computational speedup.
4. Polynomial Interpolation on a Punctured Affine Space
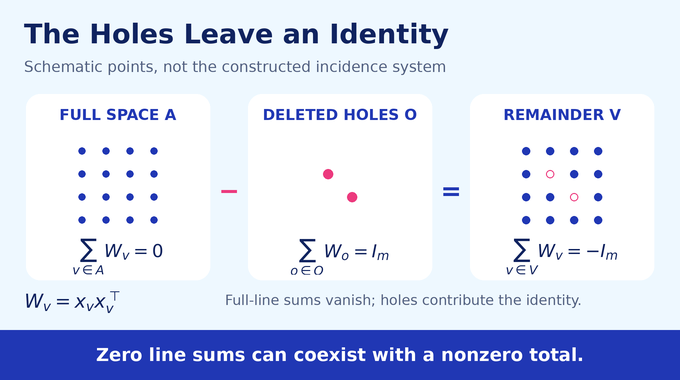
Begin with an affine space , where is a field of even order . Here names a finite field, not the rational numbers. Select holes inside an index simplex, a set whose coordinate indices have bounded total sum. Write .
Lemma 2.1 supplies interpolation polynomials that distinguish the holes. Each takes value one at its designated hole and zero at the other holes. At a point , collect their values into a column . At the deleted points, these columns are coordinate unit vectors.
The interpolants have degree at most , so their pairwise products have degree at most . Lemma 2.2 shows that such products sum to zero on every full affine line, and consequently across the whole space.
The holes contribute the identity matrix. Removing them leaves:
Here is the size- identity matrix and the superscript means transpose, without complex conjugation. In characteristic two, negative and positive identity agree. Keeping the minus sign makes the subtraction behind Proposition 2.3 visible.
For a small illustration, when , the interpolants have degree at most one and their products degree at most two. The vanishing lemma still applies. That example illustrates the degree calculation only. The full geometry requires sufficiently large parameters, not an arbitrary four-element toy model.
5. Building High-Girth Finite Geometry With Affine Lines
The remaining points need a carefully organized family of full lines. Every point must lie on exactly lines, for an odd prime , while the bipartite point-line incidence graph must have girth at least 12. Girth is the length of a shortest cycle.
Simply deleting lines through holes would damage neighboring points’ degrees. Section 5 instead uses local trades. In a plane through a hole, remove a fan of lines and insert parallel lines avoiding the hole. Every other affected point loses one incidence and gains one.
Compatible holes prevent conflicting trades and certain rectangles. Random three-dimensional slabs control additional short polygons. A weighted Lovász local lemma proves that all the relevant bad events can be avoided simultaneously. Thus exact regularity survives while triangles, rectangles, and pentagons of lines disappear.
Linnik’s prime bound supplies compatible parameters with controlled growth. The paper proves the remaining geometric and probabilistic ingredients internally. Randomness establishes existence here. Section 6 later replaces unspecified successful choices with finite enumeration.
6. The Incidence Criterion That Connects Geometry to Group Algebra
Theorem 3.1 packages the geometric input into an algebraic criterion. Let . Besides regularity and girth, it requires:
The total pairing is the identity with a minus sign, while every retained line has zero pairing:
Here denotes the line family. These are finite matrix identities over the coefficient field, with distinct jobs in the proof.
6.1. What Each Incidence Condition Controls
| Requirement | Role In The Proof |
|---|---|
| Degree at every point | Matches the one-dimensional subgroups in each local group. |
| Incidence girth at least 12 | Prevents local subgroup collapse through a planar contradiction. |
| Zero line sums; total | Produces the forward matrix identity through cancellation. |
| Provides enough character channels to pack intermediate coordinates. | |
| Forces the reverse-product defect through a rank inequality. |
There is an apparent paradox: adding all the zero line sums seems as though it should recover the nonzero total. But every point appears times. That number is even and therefore zero in characteristic two. The combined line sum multiplies the total by zero. This parity makes the characteristic-two construction compatible with regularity.
7. Why Euler’s Formula Keeps the Local Groups Embedded
At each point, install a copy of the additive group . Its one-dimensional subgroups correspond to the incident lines. Shared line generators glue these local groups into a larger group .
Relations could accidentally identify a nonidentity local element with the identity. Preventing that collapse is indispensable. The subsequent averages and character calculations require actual embedded finite subgroups, rather than merely names in a presentation.
Lemma 3.2 converts a hypothetical collapse into a planar balance diagram. After reductions, black vertices have degree at least three. Ordinary white vertices have degree at least two, with one possible exceptional vertex. Incidence girth forces all but at most one face to have boundary length at least 12.
These bounds imply that vertices plus faces are at most edges plus three-halves. Euler’s formula requires edges plus two. The contradiction proves injectivity of every local group map. As in our Barnette’s conjecture explainer, planar counting constrains an apparently different mathematical object, although the constructions are separate.
8. Subgroup Averages Create a Rectangular One-Sided Inverse
For an embedded local subgroup of order , define its normalized average:
The denominator is invertible because is odd. Each average is idempotent, meaning . Multiplying an average by itself counts every subgroup element exactly times before normalization.
Set the column of indexed by to , and the corresponding row of to . Let be the diagonal matrix of the averages. Then:
The calculation expands each point-group average through its incident line subgroups. Every line contribution disappears because its vector pairing sums to zero. The cancellation is coordinated across the incidence system, rather than obtained by simplifying each average separately. The remaining total contribution gives the identity.
But has rows and columns, while has the reverse dimensions. Rectangular matrices can have one-sided inverses even over ordinary fields. This is useful intermediate data, not yet the desired failure of direct finiteness.
9. How Character Idempotents Pack Rectangular Data Into Square Matrices
The proof adjoins a cyclic group of order , then uses an HNN extension to implement prescribed subgroup isomorphisms by conjugation. An HNN extension adds generators that conjugate selected subgroups onto one another. Our Boone–Higman proof analysis provides related embedding background.
The extension also needs an embedding certificate. The authors construct a permutation action whose restriction to the original group is faithful, so adjoining the conjugating generators does not destroy the previously protected subgroup algebra.
A primitive th root of unity supplies character idempotents. These act as mutually orthogonal algebraic channels: distinct characters multiply to zero. The local two-dimensional group has characters, allowing that many channels per coordinate slot.
Since , every intermediate coordinate receives a distinct slot-and-character pair. Packing matrices and satisfy , where is a central idempotent selecting a cyclic character.
Define:
The complementary terms restore the identity outside the selected component. Orthogonality eliminates unwanted cross terms, and the rectangular identity gives . The factors are now square. Proving the reverse product fails remains a separate obligation.
10. The Rank Obstruction: Why the Reverse Product Cannot Be One
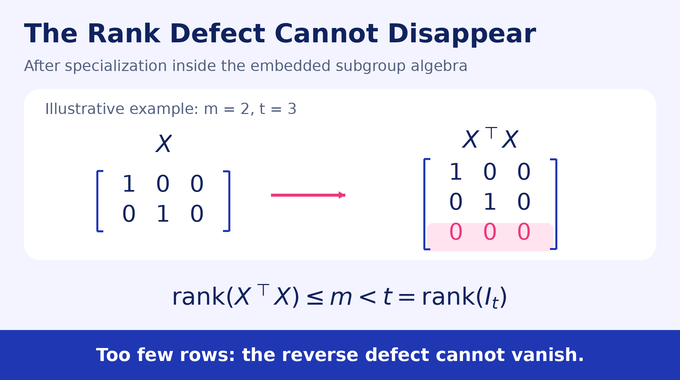
Write . Multiplying this defect on the left by and on the right by gives:
Crucially, the right-hand side lies in an embedded subgroup algebra , with . There is a homomorphism from this smaller algebra to sending elements of to one and to the chosen root of unity.
Let be the matrix of columns . Under that homomorphism, the sandwiched defect becomes:
The reason is elementary: has rank at most , whereas has rank . Equivalently, any nonzero vector in the kernel of detects the difference.
The embedding preserves this nonzero element in the larger algebra, proving . The scalar homomorphism is used only on the subgroup algebra. Extending it to the whole construction would be an unjustified shortcut and would undermine the argument.
11. From a Matrix Defect to the Final Scalar Counterexample
The final conversion uses a finite auxiliary group , where the symmetric group permutes coordinates. Character idempotents and coordinate swaps produce matrix units inside .
They define an injective algebra map from the matrix algebra into . Its identity lands at an idempotent , the identity of the image corner. The corner associated with an idempotent consists of elements in the surrounding ring and has identity .
Add the complementary identity to obtain:
The forward product is one. The reverse defect is , nonzero by injectivity. Finite presentations survive every construction step, and the embedded odd-order elements survive too.
Section 6 fixes choices by ordered finite searches. Existence guarantees termination, while algebraic certificates establish the products without solving the group word problem. Unlike an efficiency guarantee such as the one discussed in our matroid counting analysis, termination supplies no practical runtime promise. The manuscript explicitly says the full prescription has not been executed.
The parameter choices explain the caution. The search takes , chooses the least prime congruent to minus one modulo , and examines finite hole-and-line families. It eventually succeeds by the existence theorem. Neither the word “finite” nor a proof of termination promises that these objects can be listed within available computing resources.
12. What the Proof Establishes About Nonsofic Groups and Cellular Automata
The constructed group is nonsofic: otherwise Elek–Szabó’s stable-finiteness theorem would prohibit its scalar defect.
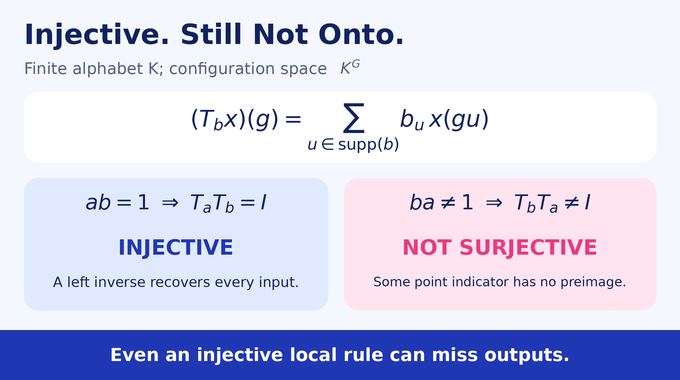
For the cellular automaton consequence, a configuration is any function from to the finite alphabet . A finite sum defines the local rule:
Only finitely many coefficients contribute. The configuration itself may have infinite support. Finite memory describes what one update reads at each position, not how much information the entire configuration contains. With this right-neighbor convention, . Therefore has left inverse and is injective. Its image consists exactly of configurations fixed by . A nonzero coefficient of identifies a point-indicator configuration outside that image, disproving Gottschalk’s surjunctivity conjecture.
The official Lean scope note reports formalization of the characteristic-two counterexamples, including finite presentation, odd-prime torsion, and termination. It explicitly excludes nonsoficity from those statements. The linked comparison targets specify statements to be checked against solution modules. A challenge statement alone is not the completed proof. The public solution source supplies the theorem and its imported construction, but we have not independently rebuilt the formalization. Our Fermat formalization explainer explains why checking a formal theorem’s scope matters.
The Kaplansky Direct Finiteness Conjecture now has a manuscript counterexample with documented formalization, rather than a small executable demonstration. Its useful lesson is the separation of cancellation, preservation, and defect detection. Follow Binary Verse AI for research explainers that make those mechanisms understandable while keeping their assumptions visible.
What is Kaplansky’s direct finiteness conjecture?
Kaplansky’s direct finiteness conjecture states that every group algebra , over any field and group , is directly finite. Whenever , it predicts . The question is whether one-sided inverses must always be two-sided in group algebras.
Has Kaplansky’s direct finiteness conjecture been disproved?
OpenAI’s September 23, 2026 preprint presents a counterexample: a finite characteristic-two field, a finitely presented group, and group-algebra elements with but . This contradicts the unrestricted conjecture. OpenAI’s scope documentation reports Lean formalization of the characteristic-two counterexamples. This article does not independently rebuild that formalization or certify journal peer review.
How does OpenAI’s proof construct a counterexample?
Polynomial interpolation and a high-girth incidence system of affine lines supply matrix identities. A planar argument keeps finite local subgroups embedded. Subgroup averages and character idempotents turn a rectangular factorization into square matrices with a one-sided inverse. A rank obstruction detects the reverse defect, and matrix units convert the matrices into two ordinary group-algebra elements.
Why is characteristic two essential to this construction?
Every point has incidence degree , where is an odd prime. That degree is even and therefore zero in the coefficient field. Summing all the zero line pairings consequently multiplies the nonzero total pairing by zero, so the two requirements are compatible. This cancellation is essential to this construction, rather than a claim that analogous counterexamples cannot exist in other positive characteristics.
Does the proof give a torsion-free counterexample over the two-element field?
No. This paper deliberately constructs a group containing an element of odd prime order and uses a finite characteristic-two field without asserting . Its witnesses are specified by a terminating prescription, but the manuscript says the full prescription has not been executed. Stronger torsion-free assertions require separate results and are not conclusions of this paper.
Does the counterexample also disprove Gottschalk’s surjunctivity conjecture?
Yes, as a consequence proved in the manuscript. The scalar witnesses define a cellular automaton on all configurations over the finite alphabet . The relation supplies a left inverse for the automaton defined by , making it injective. The defect identifies a configuration outside its image. The group is also nonsofic, since sofic group algebras are stably finite.
Has OpenAI’s proof been formally verified in Lean?
The official scope note reports formalized characteristic-two direct-finiteness counterexamples, including a finitely presented group with odd-prime torsion and a terminating witness prescription. The public solution module states the corresponding existential theorem and construction certificates. Nonsoficity is explicitly outside those specified formal statements. This article inspected the documentation and theorem source but did not independently rebuild or audit the full Lean dependency tree.